
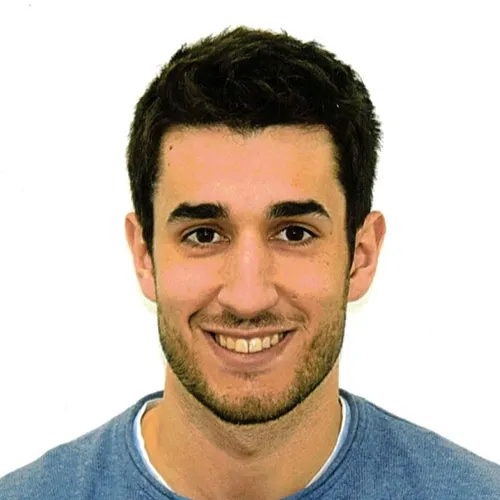
- jorge.borrell@universidadeuropea.es
- Escuela de Ciencias, Ingeniería y Diseño - Valencia
Profesor adjunto
Dr. Jorge Borrell Méndez
- Ciencias
- Ingeniería
Jorge Borrell Méndez es profesor e investigador de la Escuela de Ciencias, Ingeniería y Diseño (STEAM).
Es Graduado en Ingeniería Electrónica y Automática Industrial, Máster en Ingeniería Industrial y Doctor en Estadística, optimización y Matemática Aplicada por la UMH.
Sus lineas de investigación actuales se centran en el desarrollo de aplicaciones de Inteligencia Artificial.
Formación académica
Doctor en Estadística, Optimización y Matemática Aplicada
- UMH
- 2019 - 2024
Experiencia profesional
Titulaciones
Publicaciones
Francisco José Martínez-Peral, Jorge Borrell Méndez, Dennis Mronga, José Vicente Segura-Heras, Carlos Perez-Vidal, Trajectory planning system for bimanual robots: Achieving efficient collision-free manipulation, Robotics and Autonomous Systems, Volume 194, 2025, 105118, ISSN 0921-8890
Pick-and-place operations are non-value-added activities but essential in many industrial processes. Some of these operations must be performed by dual-arm robots, which represent new challenges in terms of collision-avoidance due to the use of a shared workspace. This work addresses these two issues by proposing a Task and Motion Architecture (TMA) designed to optimize pick-and-place tasks, ensuring efficient and safe operation through collision-free movements.
Borrell, Jorge Perez-Vidal, Carlos Segura, Jose Vicente 2024/02/01 Optimization of the pick-and-place sequence of a bimanual collaborative robot in an industrial production line The International Journal of Advanced Manufacturing Technology
This paper focuses on optimising pick-and-place tasks performed by a dual-arm collaborative robot in a specific shoe manufacturing industry environment. The robot must identify the pieces of a shoe placed on a tray, pick them up, and place them in a shoe mold for further processing. The shoe pieces arrive on the tray in random positions and angles and can be picked up in a different order. Optimising these tasks could increase the assembly speed of each unit and improve shoe production.
J. Borrell Méndez, C. Perez-Vidal, J. V. Segura Heras and J. J. Pérez-Hernández, ""Robotic Pick-and-Place Time Optimization: Application to Footwear Production,"" in IEEE Access, vol. 8, pp. 209428-209440, 2020, doi: 10.1109/ACCESS.2020.3037145. keywords: {Footwear;Manipulators;Data models;Trajectory;Decision trees;Collision avoidance;Task analysis;Classification;decision tree algorithms;optimization;pick-and-place;dual arm robotics},
This article considers the problem of optimizing the task sequences carried out by a dual-arm manipulator robot in a footwear production setting. The robot has to identify the pieces of a shoe put in a tray and pick-and-place them in a shoe mould for further processing. The shoe pieces arrive on a tray in random positions (patterns) and can be picked up in different order.
Proyectos de investigación
impresión 3D robótica
Desarrollo de trayectorias para realizar impresión 3D con un brazo robótico industrial.
Pick and place con robot bimanual
Desarrollo de algoritmos para optimizar la tarea de pick and place mediante un robot bimanual colaborativo.